2023
1
Metal fabrication, Automotive, Consumer industry
25 - 35 CW
Depends on the final process
Cat. 200k - 250k EUR
Handling, Measuring, Cleaning, Optical inspection, Sorting, Marking
Fanuc, Keyence, Siemens, Festo, Schunk
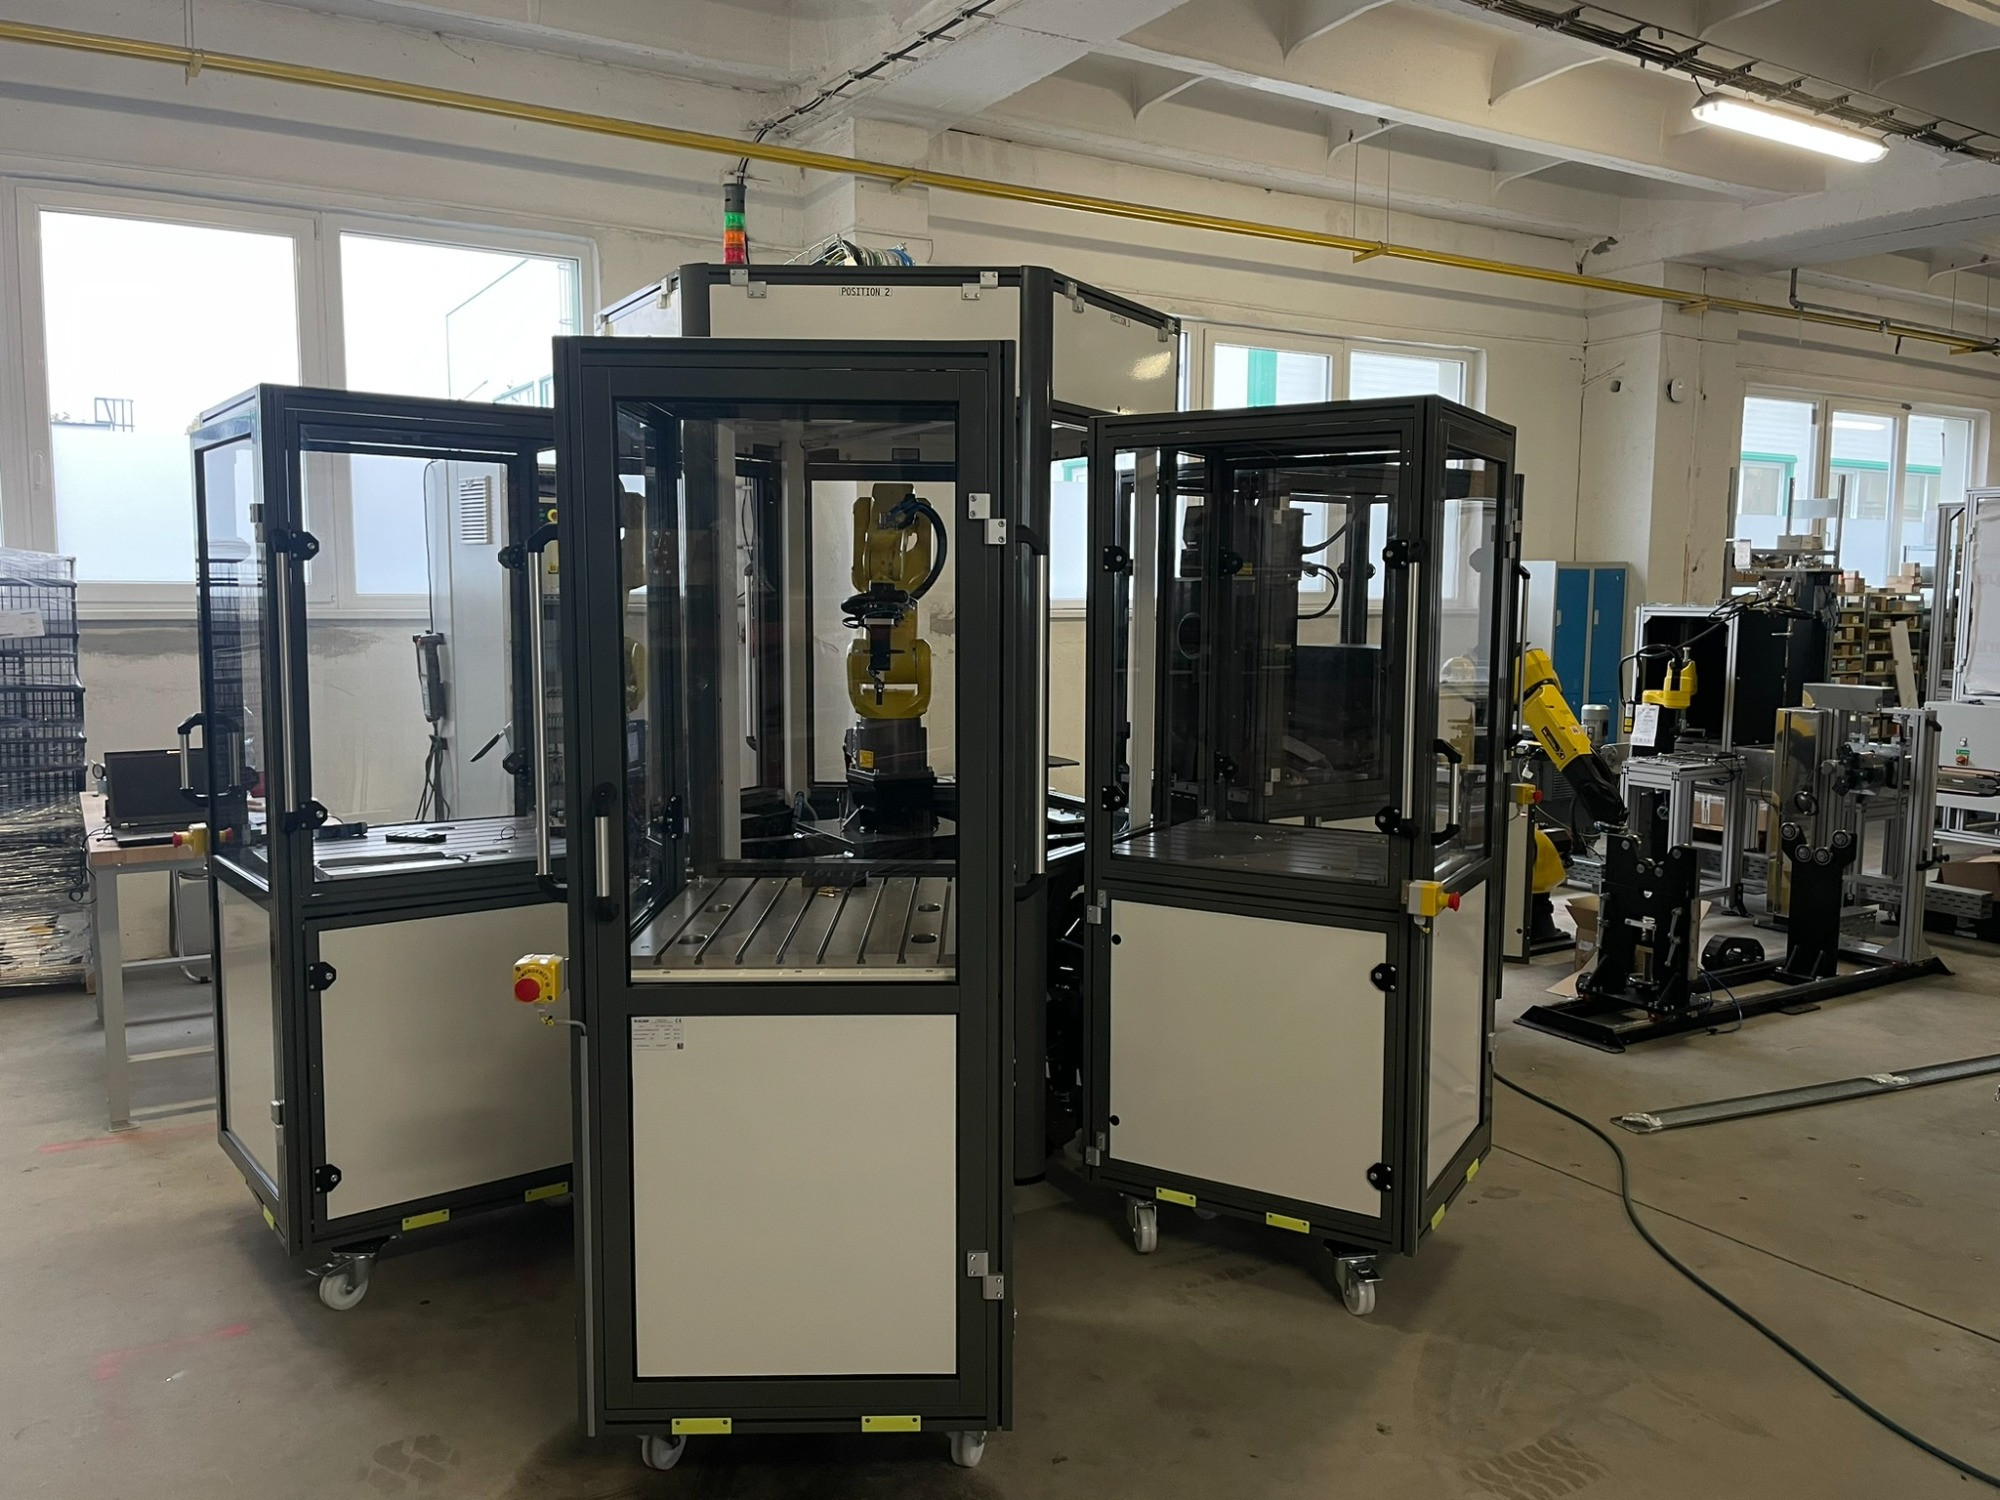
The customer specializes in the production of specialized machine tools with deliveries worldwide. Due to the customer's focus on the automotive and aerospace sectors, particular emphasis is placed on the quality of the goods supplied. Due to the enormous variability of piece production and the shortage of workers on the market, full automation of the process was adopted. With a strong vision to expand the product range and the need to respond to turbulent changes in the future, the customer chose automation in the form of the HXG platform, which allows them to respond to change better than a single-purpose machine.
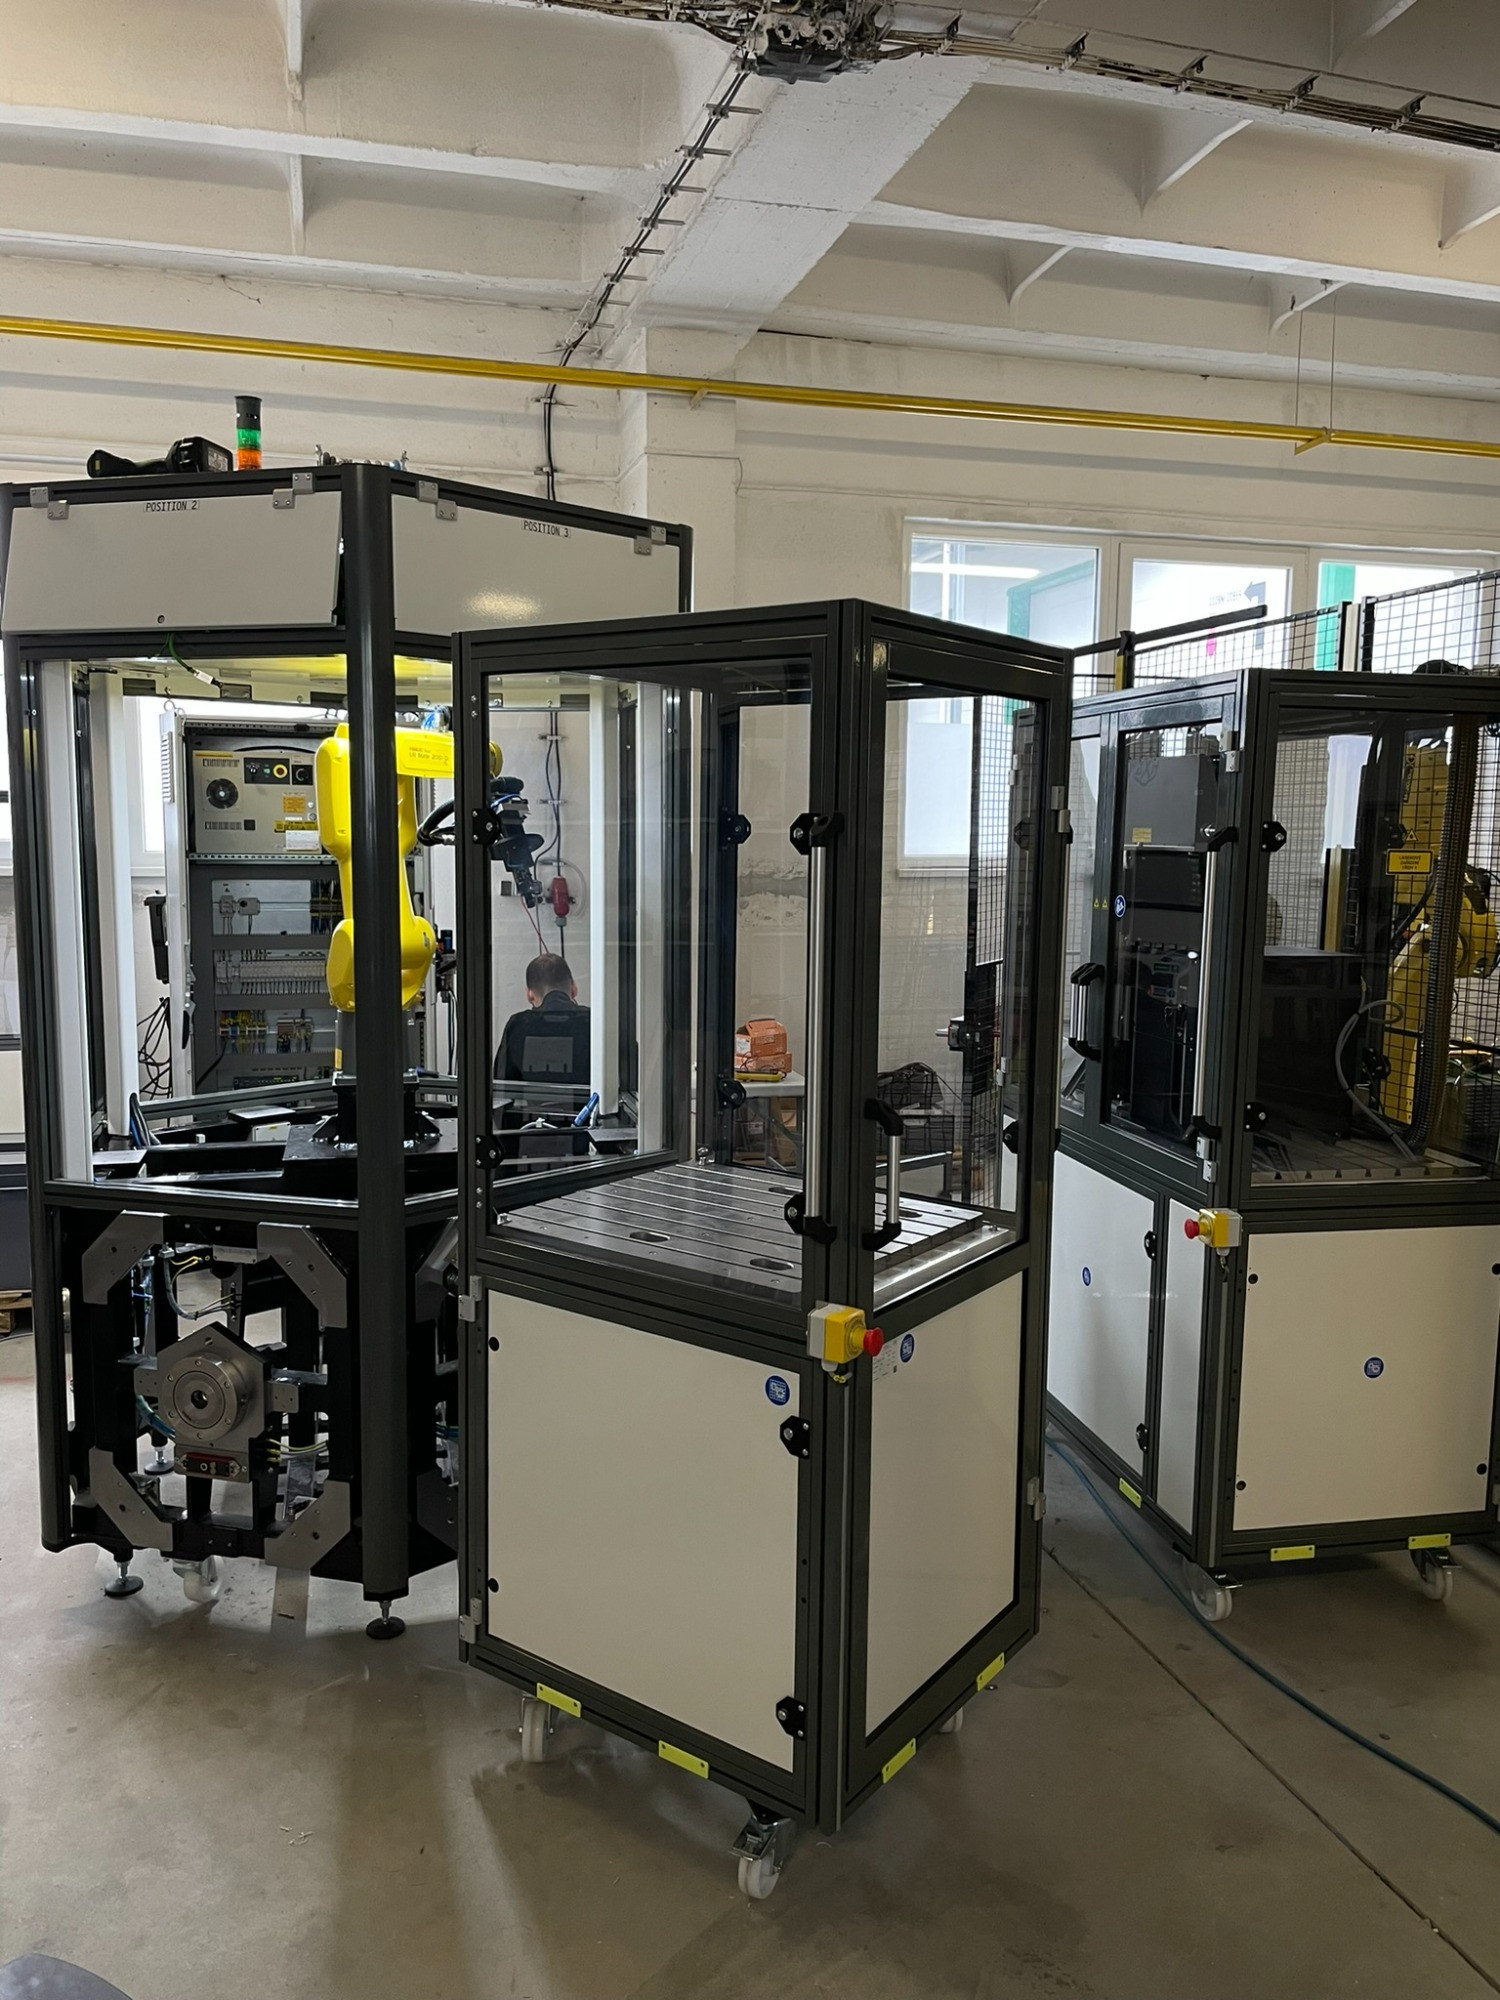
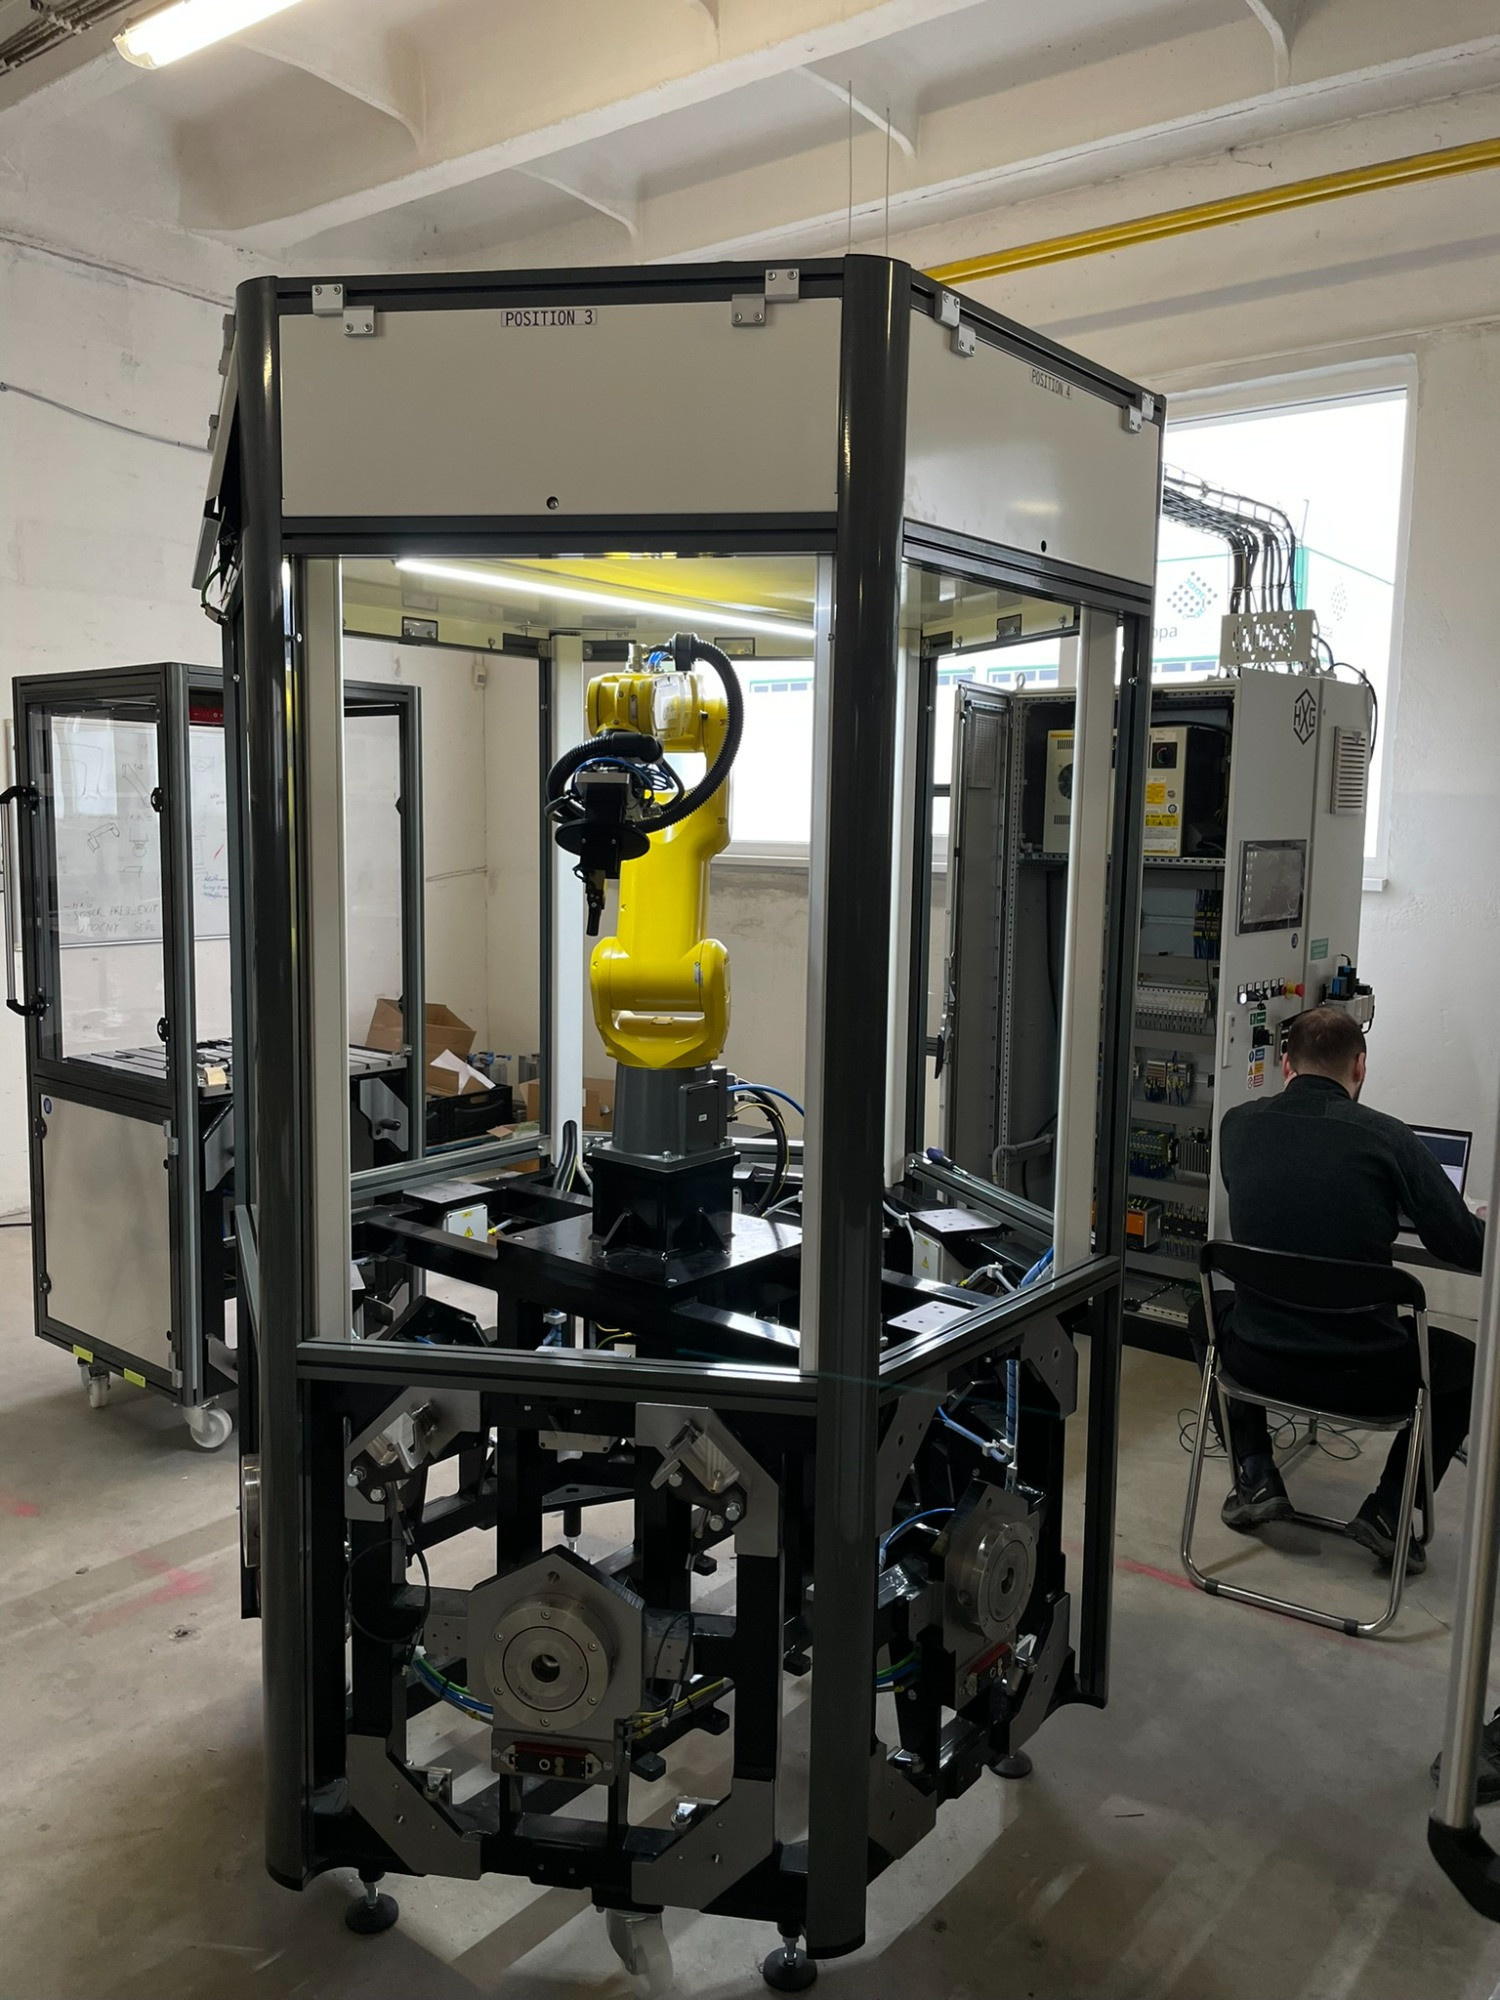
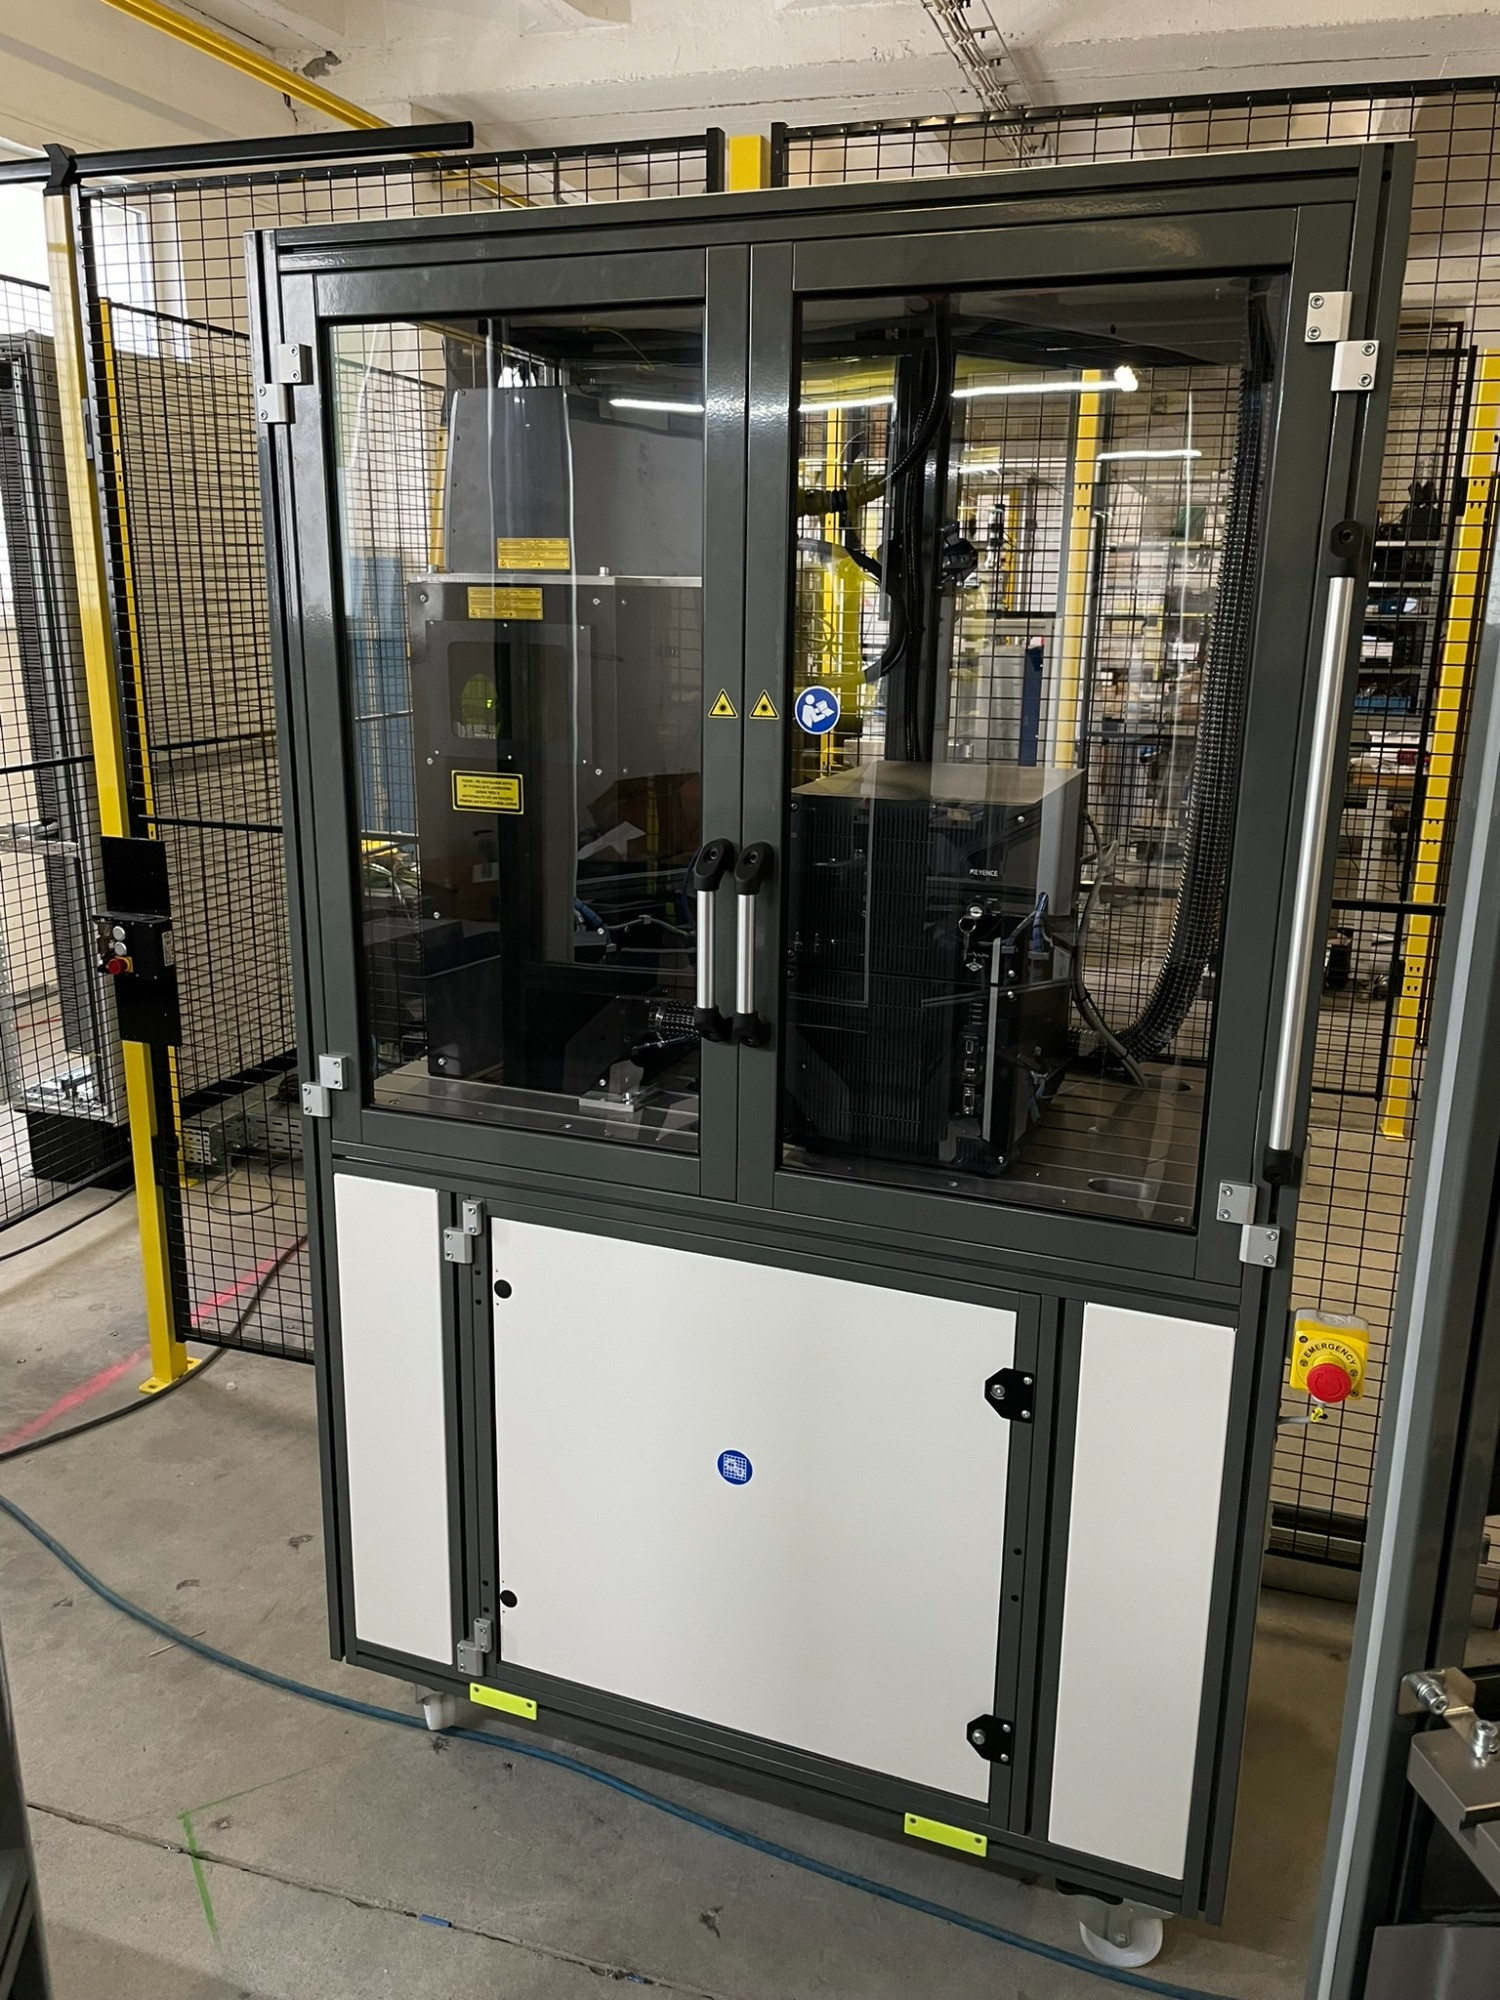
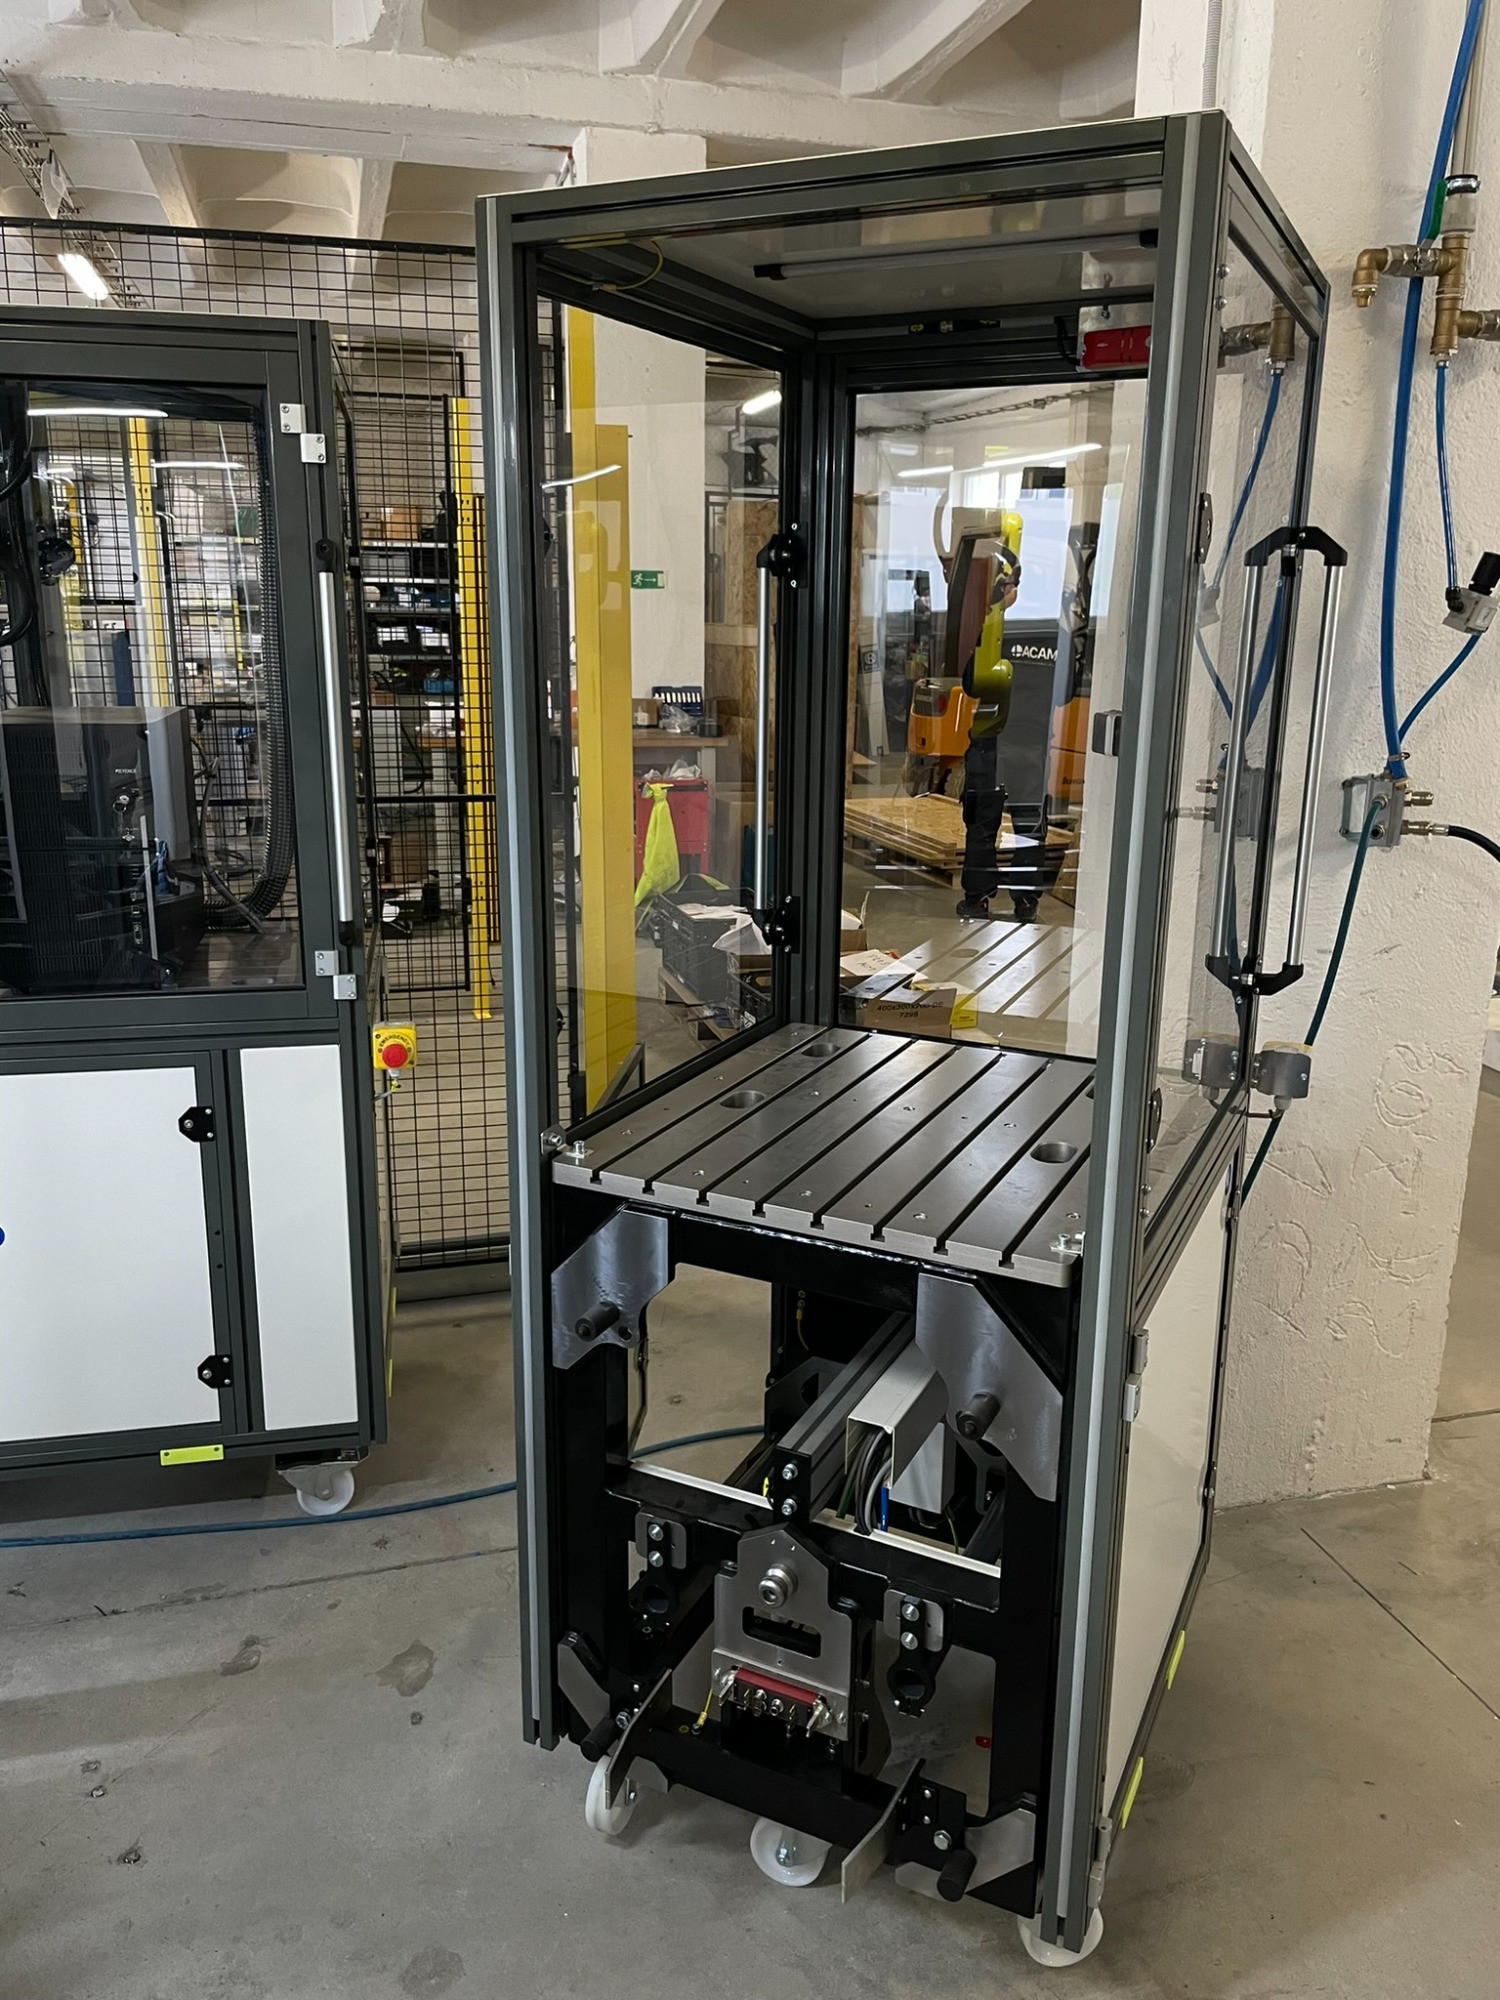
The subject of the implementation was the development and delivery of equipment for 100% optical output inspection and marking of machine tools. The main parameters to be checked are length, shape and absence of defects. The customer develops the inspection module in cooperation with another entity.
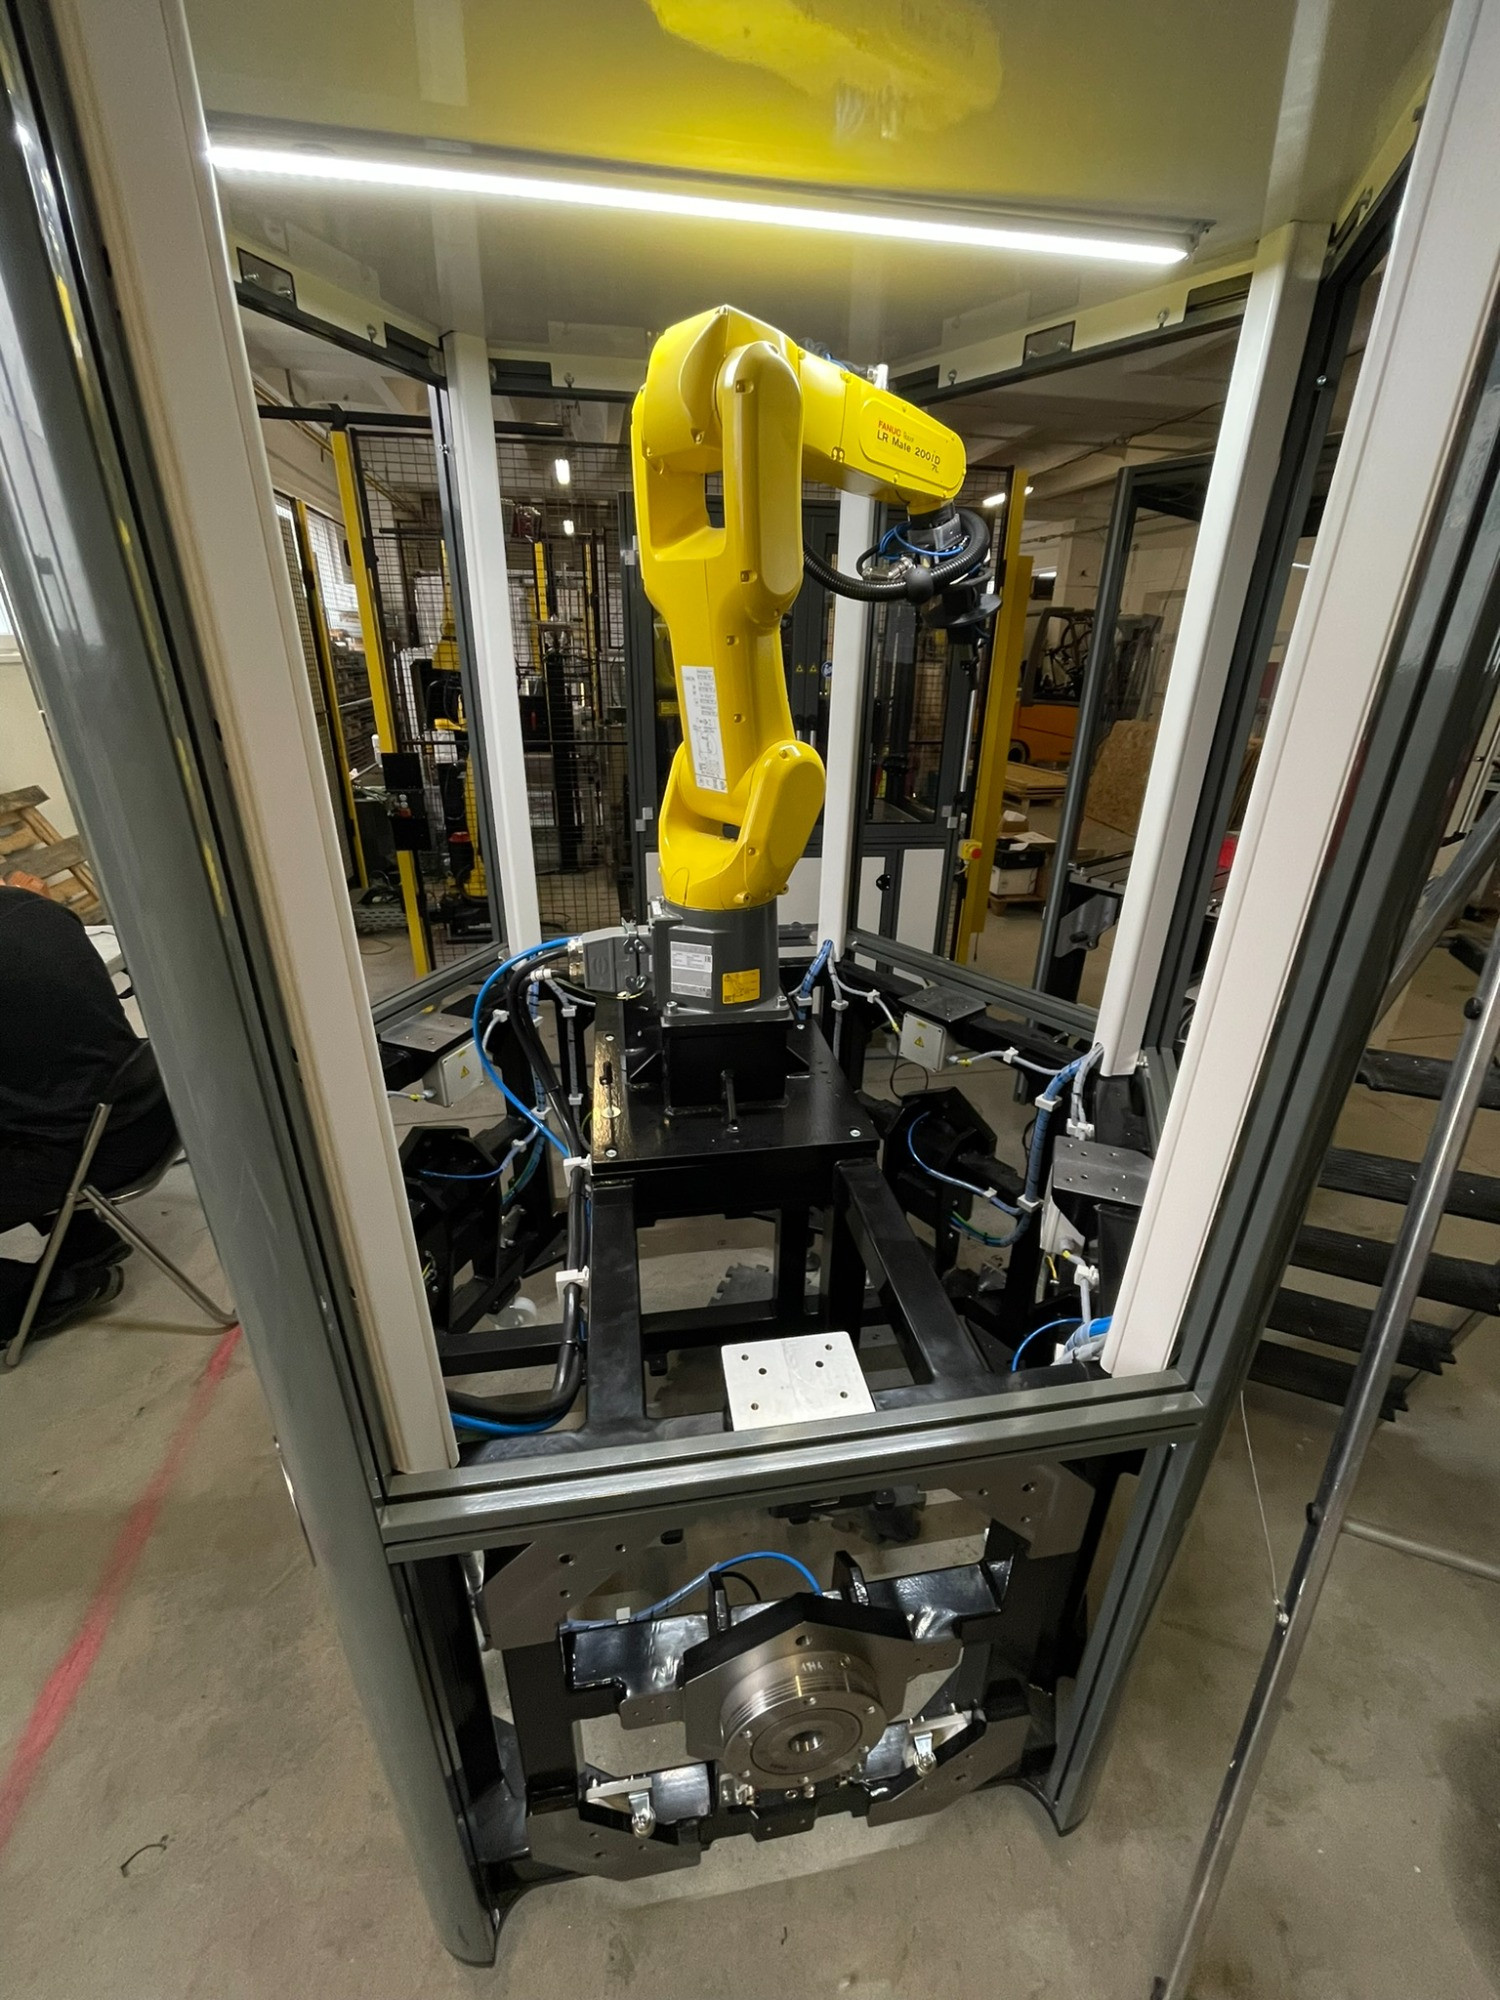
In terms of the customer's needs, the equipment was designed on the HXG platform - a reconfigurable robotic platform in configuration:
Process description:
Whether you are looking for a supplier of complex system integration, a specific service, or simply need advice.

Each project is unique, but they are all united by automation. It gives you an idea of our capabilities, whether it's robotic applications, our HXG platform, control and single-purpose equipment. We can automate anything.


This site is protected by reCAPTCHA and the Google Privacy Policy and Terms of Service apply.
